Gyeongsu (Bob) Cho

Seeking a Summer 2027 research internship. I am a Ph.D. student in the Artificial Intelligence Graduate School at UNIST, where I am a member of the 3D Vision & Robotics Lab under Prof. Kyungdon Joo's supervision. My expected Ph.D. graduation is February 2028. I am a Research Intern at UT Austin, 2026–Present, working with Prof. Georgios Pavlakos and Dr. Hezhen Hu. I received a B.Eng. in Mechanical Engineering from Chung-Ang University.

Email  /  CV  /  Research Map  /  Bob Wiki  /  LinkedIn  /  GitHub

Research Internship Profile
Selected Publications  /  Academic Service  /  Seminars

profile photo

News

  • 2026: AniGauss was accepted to CV4Animals Workshop @ CVPR 2026.
  • 2026: WildAni4D was accepted to CVPR 2026 Findings.
  • 2025: Pose-Diverse Multi-View Virtual Try-on was accepted to WACV 2026.
  • 2025: Avatar++ was accepted to Wild3D Workshop @ ICCV 2025.
  • 2025: DogRecon was accepted to International Journal of Computer Vision (IJCV).

Research

I study 3D/4D reconstruction of articulated humans and animals from single images and monocular videos, recovering shape, appearance, pose, motion, and world-space trajectories. My work combines parametric body priors, topology-aware Gaussian representations, synthetic-video supervision, and temporal modeling to produce animatable representations. My research agenda connects controllable human and animal avatars with reusable motion; contact-aware motion and physics-grounded interaction are future directions.

Manuscripts & Ongoing Research

  • AniGauss++ — Manuscript submitted to IJCV.
  • Multi-Dancer Generation — Sony × UT Austin research collaboration; Manuscript in preparation for CVPR.
  • Animal Agent — Manuscript in preparation for CVPR.
  • Animal Motion — Manuscript in preparation for CVPR.

Selected Publications

AniGauss animal reconstruction
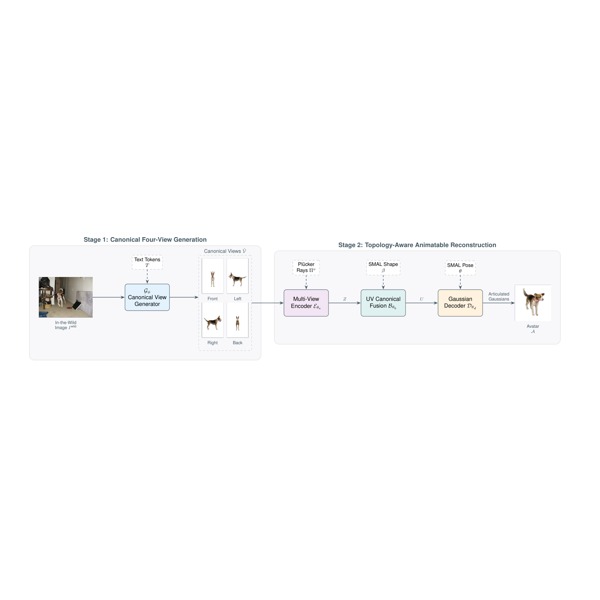
AniGauss: Toward Animatable Animal Reconstruction from Single In-the-Wild Images via Topology-Aware Gaussians
Gyeongsu Cho, Changwoo Kang, Donghyeon Soon, Hezhen Hu, Kyungdon Joo
CV4Animals Workshop @ CVPR 2026
[paper]  /  [project page]

We present a topology-aware Gaussian framework for animatable animal reconstruction from a single in-the-wild image.
4D animal mesh reconstruction
WildAni4D: Towards 4D Animal Mesh Reconstruction
Gyeongsu Cho, Hezhen Hu, Donghyeon Soon, Changwoo Kang, Kyungdon Joo
CVPR 2026 Findings
[paper]  /  [project page]

We present a synthetic animal video pipeline and a video transformer model for reconstructing temporally coherent 4D animal motion and global trajectories from monocular in-the-wild videos. This project is part of a research collaboration with UT Austin.

Synthetic test set: MPJPE 91.29 and Shape Consistency 0.0703 (lower is better; units are not specified in the table). [paper, Table 1]

Pose-diverse virtual try-on
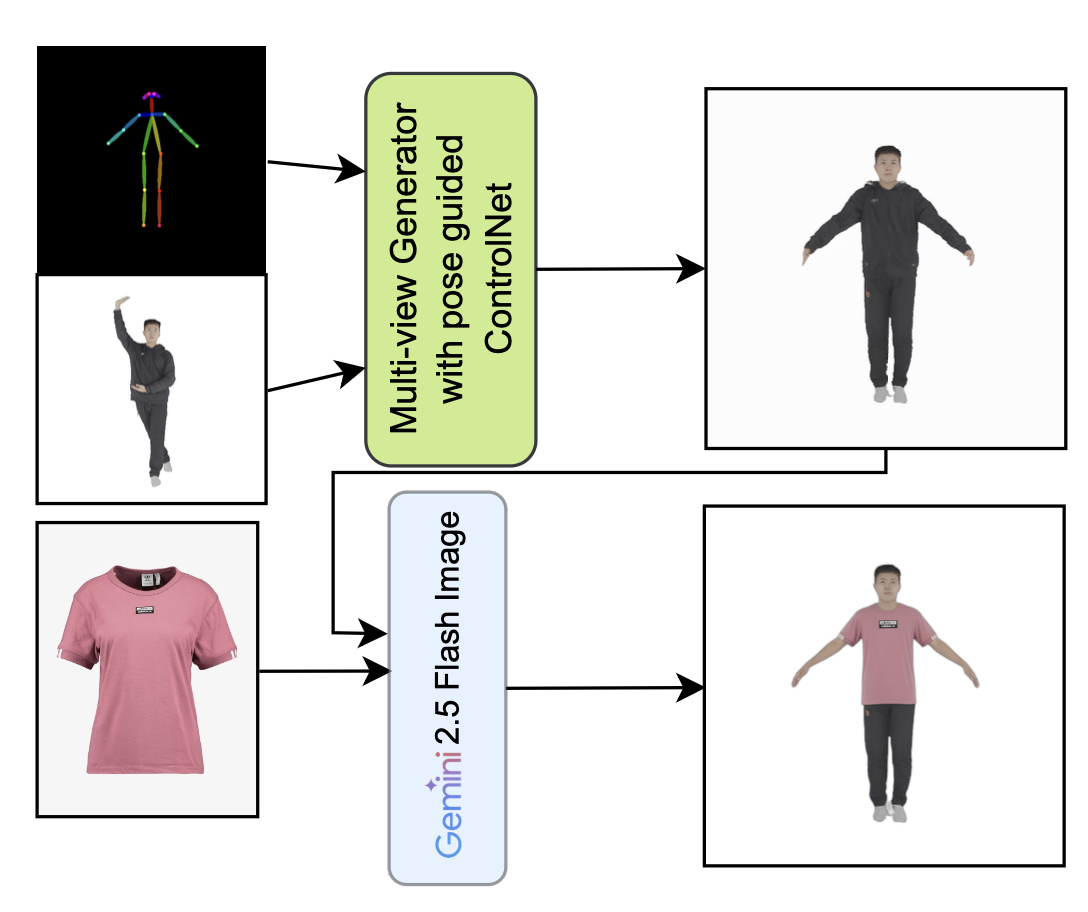
Pose-Diverse Multi-View Virtual Try-on from a Single Frontal Image
Seonghee Han*, Minchang Chung*, Gyeongsu Cho, Kyungdon Joo, Taehwan Kim
WACV 2026
[paper]

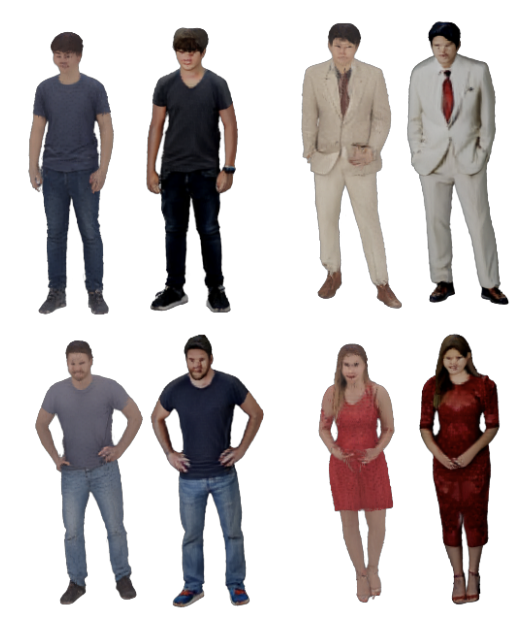
This work generates pose-diverse, multi-view images for virtual try-on starting from a single frontal input. By leveraging multi-view consistency and pose conditioning, the method produces realistic, view-consistent outfits under large pose variations.
Avatar++
Avatar++: Fast and Pose-Controllable 3D Human Avatar Generation from a Single Image
Seonghee Han*, Minchang Chung*, Gyeongsu Cho, Kyungdon Joo, Taehwan Kim
Wild3D Workshop @ ICCV 2025


Avatar++ studies fast, pose-controllable 3D human avatar generation from a single image.
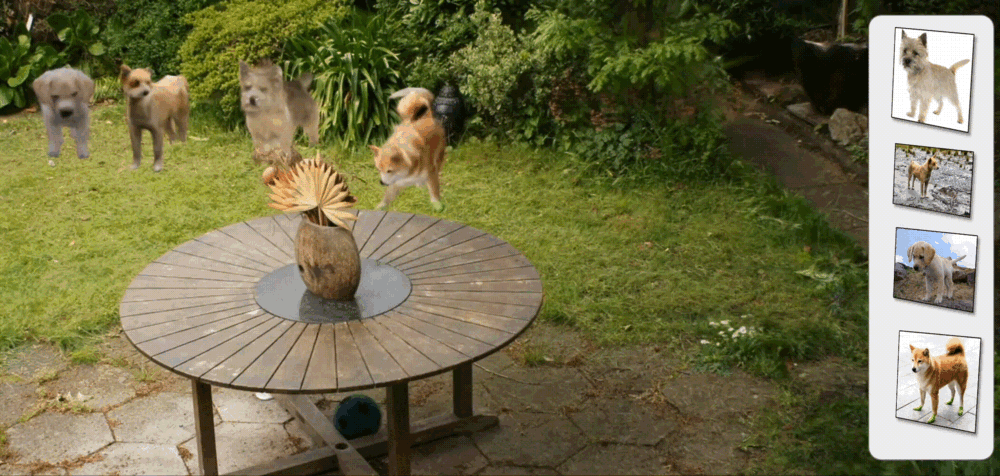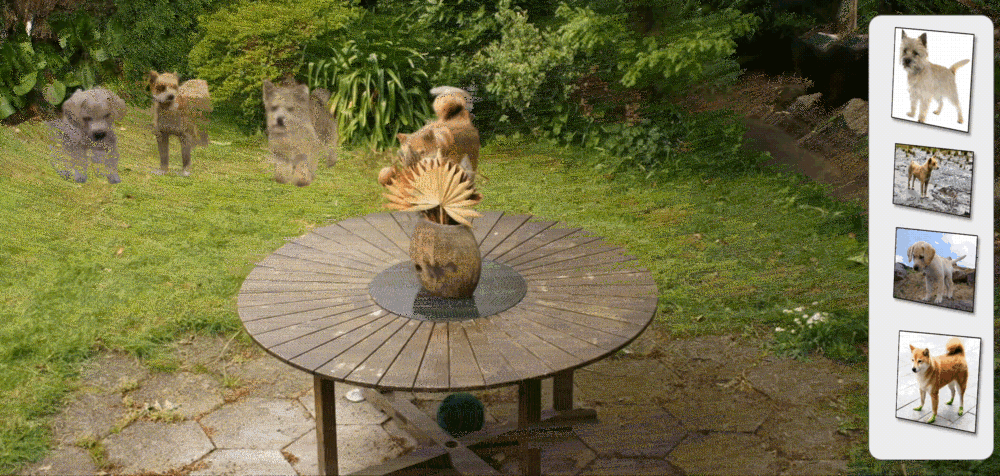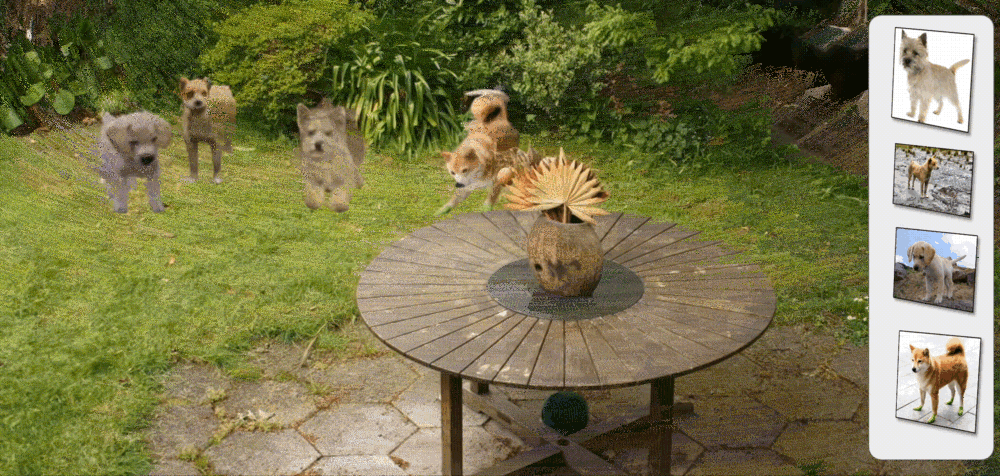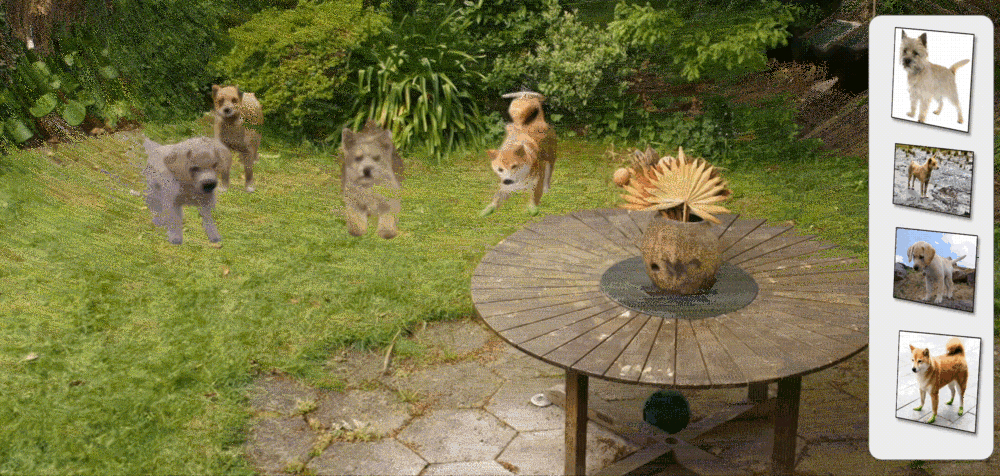
DogRecon animation
DogRecon animation base
DogRecon: Canine Prior-Guided Animatable 3D Gaussian Dog Reconstruction From a Single Image
Gyeongsu Cho, Changwoo Kang, Donghyeon Soon, Kyungdon Joo
International Journal of Computer Vision (IJCV), 2025
[paper]  /  [project page]

DogRecon is a framework that reconstructs animatable 3D Gaussian dog models from a single RGB image. It leverages a canine prior and a reliable sampling strategy to obtain high-quality 3D shapes and realistic animations of dogs from in-the-wild photos.

Internet-sourced image-to-3D test: CLIP-Similarity 0.8006, a rendered-view semantic-similarity metric rather than geometry accuracy. [paper, Table 2]

Earlier workshop version: CV4Animals Workshop @ CVPR 2024 (Oral). [workshop paper]  /  [oral video]

SlaBins depth estimation
SlaBins depth estimation base
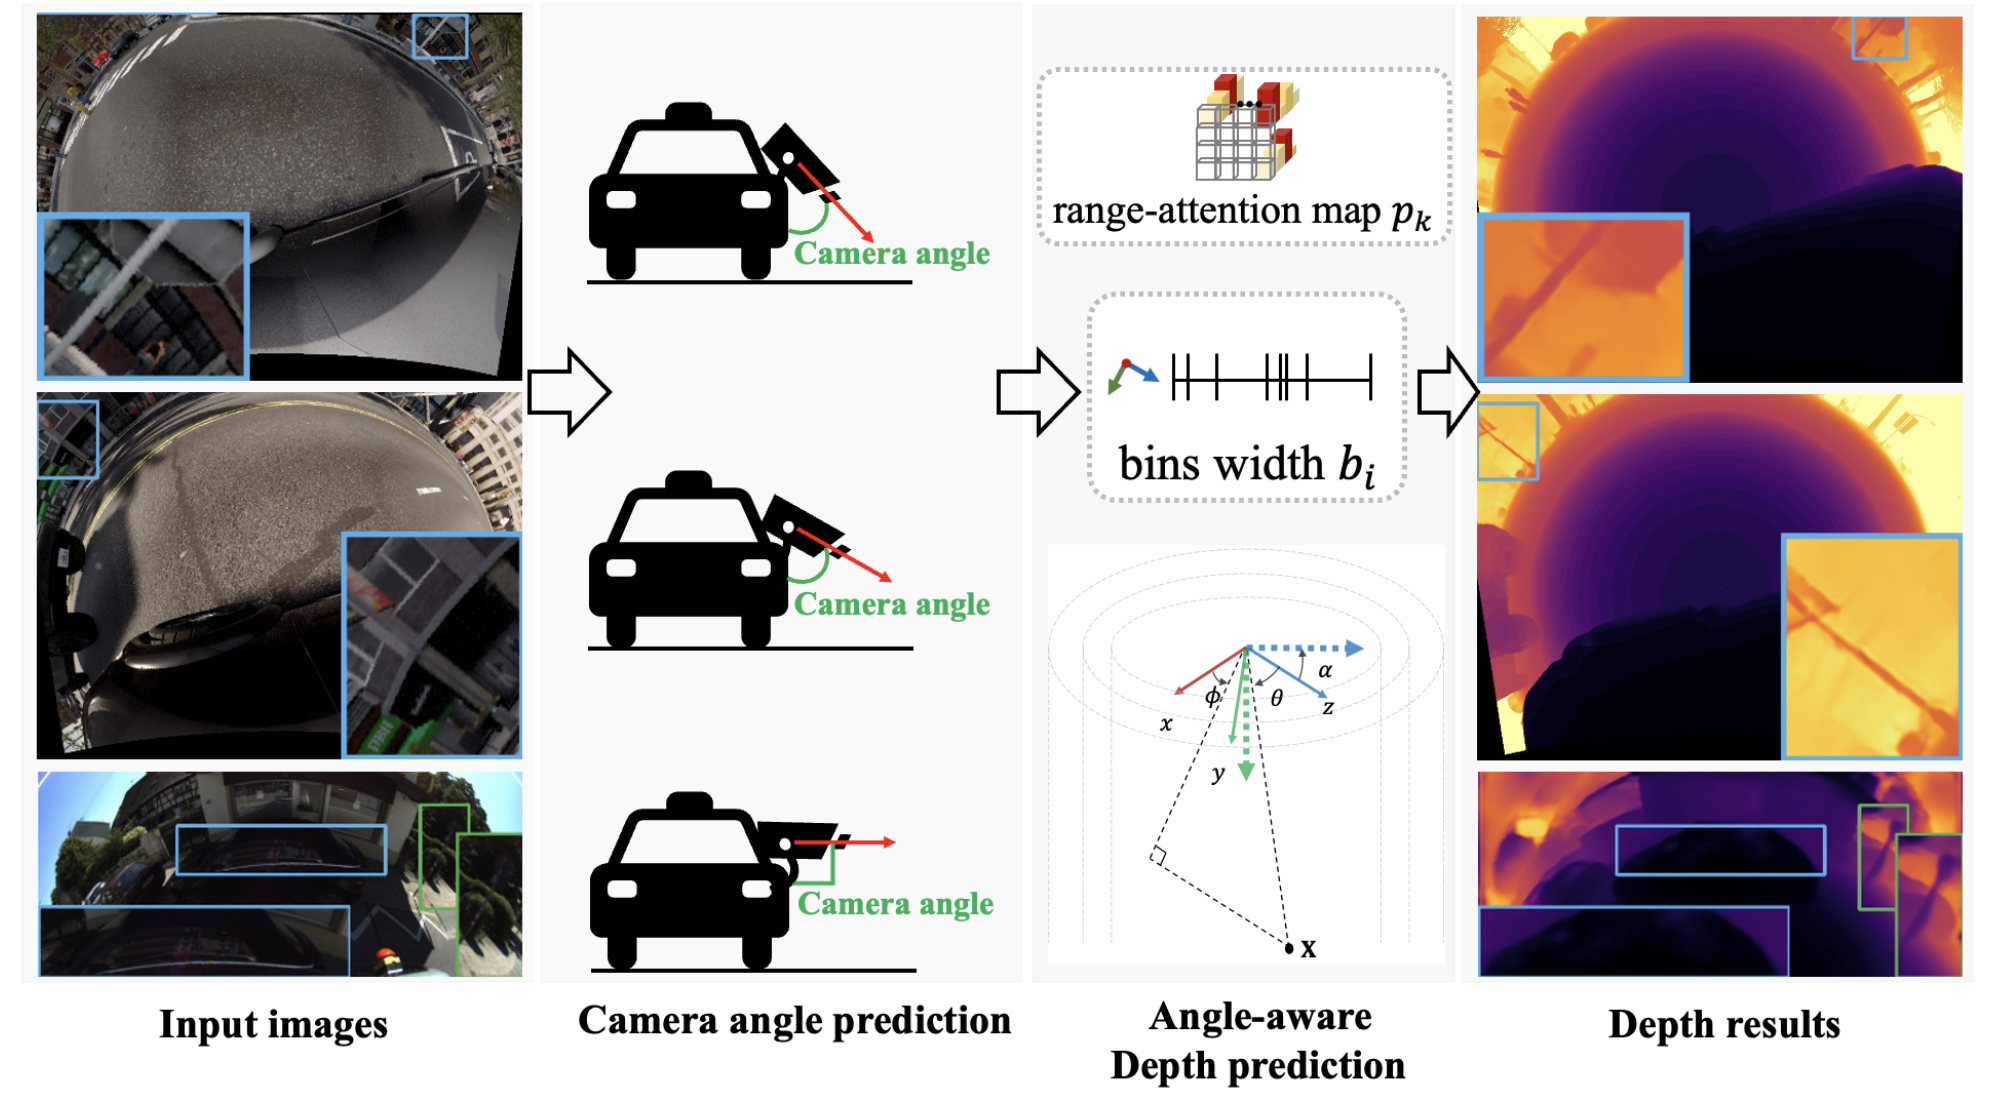
SlaBins: Fisheye Depth Estimation using Slanted Bins on Road Environments
Jongsung Lee, Gyeongsu Cho*, Jeongin Park*, Kyongjun Kim*, Seongoh Lee*, Jung Hee Kim, Seong-Gyun Jeong, Kyungdon Joo
ICCV 2023
[paper]  /  [project page]

SlaBins introduces a slanted multi-cylindrical representation and adaptive depth bins to achieve accurate and dense depth estimation from automotive fisheye cameras in road environments. This work was done in collaboration with 42dot.

Selected Seminar Slides

A small archive of research seminar slides I presented while exploring topics in 3D vision, generative models, human/animal reconstruction, and research workflows.

2026.05 Agentic Coding Workflow for Research [slides]
2025.10 From Single-Image HMR to World-Grounded Video HMR [slides]
2025.05 AniMer (CVPR 2025) [slides]
2025.02 SEVA (arXiv 2025) [slides]
2025.02 LGM: Large Multi-view Gaussian Model (ECCV 2024) [slides]
2024.12 WonderJourney (CVPR 2024) [slides]
2024.05 Generative Rendering: Controllable 4D-Guided Video Generation with 2D Diffusion Models (CVPR 2024) [slides]
2024.01 ControlNet: Adding Conditional Control to Text-to-Image Diffusion Models (ICCV 2023) [slides]
2023.09 BANMo: Building Animatable 3D Neural Models from Many Casual Videos (CVPR 2022) [slides]
2023.05 NeuMan: Neural Human Radiance Field from a Single Video (ECCV 2022) [slides]
2022.07 Digging Into Self-Supervised Monocular Depth Estimation (ICCV 2019) [slides]
2022.04 MINE: Towards Continuous Depth MPI with NeRF for Novel View Synthesis (ICCV 2021) [slides]
2022.03 PixelSynth: Generating a 3D-Consistent Experience from a Single Image (ICCV 2021) [slides]

Academic Services

  • Reviewer, CVPR 2026
  • Reviewer, ECCV 2026
  • Reviewer, CV4Animals Workshop @ CVPR 2026
  • Reviewer, 4D Vision Workshop @ CVPR 2026

Education

  • Integrated M.S.–Ph.D. in Artificial Intelligence, Artificial Intelligence Graduate School, UNIST, South Korea (2022 – Present).
    Expected Ph.D. graduation: February 2028
  • B.Eng. in Mechanical Engineering, Chung-Ang University, South Korea (2018 – 2021).

Research & Industry Experience

  • Research Intern, UT Austin, 2026–Present
    Advisors: Prof. Georgios Pavlakos and Dr. Hezhen Hu. Develop research pipelines for animatable 4D animal and human reconstruction from monocular videos.
    Multi-Dancer Generation is a Sony × UT Austin research collaboration, with the status Manuscript in preparation for CVPR.
  • Graduate Researcher, UNIST – 3D/4D Vision & Graphics (2022 – Present)
    Lead author of DogRecon (IJCV 2025), AniGauss (CV4Animals Workshop @ CVPR 2026), and WildAni4D (CVPR 2026 Findings) on single-image and 4D animatable animal reconstruction. Develop synthetic video pipelines, SMAL-based animal models, and PyTorch3D-based renderers for large-scale training and evaluation. Explore generative pipelines that lift text/video outputs into animatable 3D/4D representations.
  • Research Collaboration with Samsung Electronics – Video Anomaly Detection (2024 – 2025)
    Co-developed a reference-guided video anomaly detection framework for industrial display inspection using real manufacturing data; contributed to dataset design, model architecture, and experiments.
    Reference-Guided Video Anomaly Detection for Display Inspection — Manuscript submitted to WACV; awaiting decision.
  • Startup Project – Real-Time 3D Human Pose Estimation (KIC & GWU Program, 2024)
    Built a 3-camera real-time 3D human pose estimation system with smoothing algorithms for stable motion analysis in gyms, designed as an AI-based personal training assistant. Selected for a Korean government startup support program and an entrepreneurship program at George Washington University. Conducted 50+ interviews with fitness and healthcare professionals across major U.S. cities and refined a US-market–focused business model, ranking 1st in track.
  • Research Collaboration with 42dot – Autonomous Driving Research (Hyundai Motor Group) (ICCV 2023)
    Collaborated on autonomous driving research with 42dot, the autonomous driving division of Hyundai Motor Group. Contributed to SlaBins (ICCV 2023). [paper]

Awards & Patents

  • AI Tech Open Workshop, UNIST — Startup Track, 1st Place (2025). Research funding: KRW 30,000,000 for lightweight 3D animal reconstruction.
  • Method and apparatus for reconstructing a 3D dog Gaussian model from a single image — Korean Patent Application 10-2025-0107831; PCT/KR2025/019381.
  • Method and apparatus for generating a depth map of an image — Korean Patent Application 10-2023-0125078, with 42dot.

Teaching & Mentoring

Teaching assistant: Linear Algebra (Chung-Ang University), Computer Graphics and Introduction to AI Programming 2 (UNIST). Tutor: Hyundai Motor Company internal Python and data-analysis program.


Updated  ·  Research Intern CV  ·  Internship Profile
Template from this website.